WTBInspector: An Automated UAV-Based Wind Turbine Blade Inspection System
2 PowerChina Zhongnan Engineering Corporation Limited, Changsha, China
✉ Corresponding author
Abstract
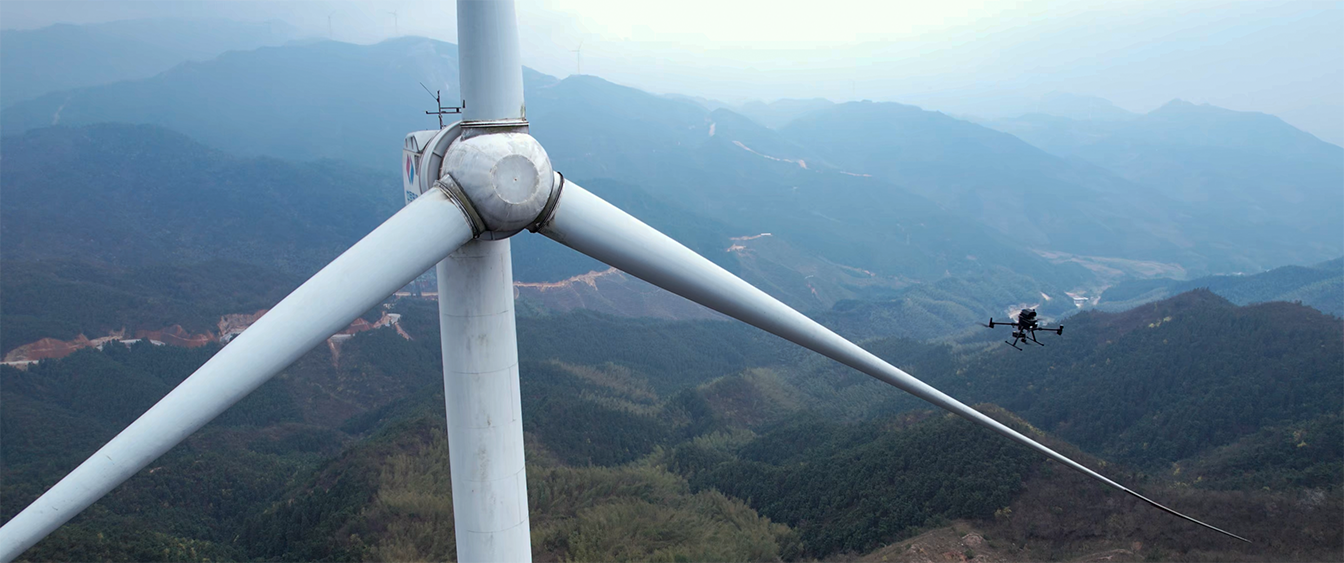
The rise of the renewable energy industry has propelled the growth of the wind power sector, escalating demands on the operation and maintenance of wind turbines. Recent advancements have integrated UAVs and automated algorithms, enhancing the efficiency of automated wind turbine blade inspection. Nonetheless, challenges persist in this field. Primarily, critical on-site parameters of stationary turbines such as turbine yaw, blade rest angle and tip position cannot be pre-obtained from the wind farm operator. Existing overviews however struggle to accurately estimate turbine tilt angle and blade tip position and have limited applicability for blade rest angle estimation. Additionally, neglect of camera orientation during blade surface tracking degrades imaging effect. Moreover, existing pipelines focus on optimizing image quality after inspection rather than in real time during acquisition, an approach that struggles to recover details lost during the imaging process. To tackle these challenges, we introduce WTBInspector: a fully automated UAV-based wind turbine blade inspection system. This system fulfills three key functions: extracting the turbine structure and estimating complete pose parameters, maintaining camera alignment with the blade surface to ensure orthogonal imaging during blade tracking, and dynamically enhancing image quality in real time during image acquisition. Integrating hardware and software and a ground monitoring application, the system enables efficient and high-quality inspection. Over 600 field inspections have been conducted on 10 distinct wind turbine models across 5 operational wind farms. These inspections covered complex hilly terrain and up to 10 m/s winds, achieving a 99.98% blade surface coverage rate. Except for unsuitability in extreme weather such as heavy rain or dense fog, the field tests confirm that WTBInspector exhibits robustness, applicability and effectiveness.
Overview
System Framework
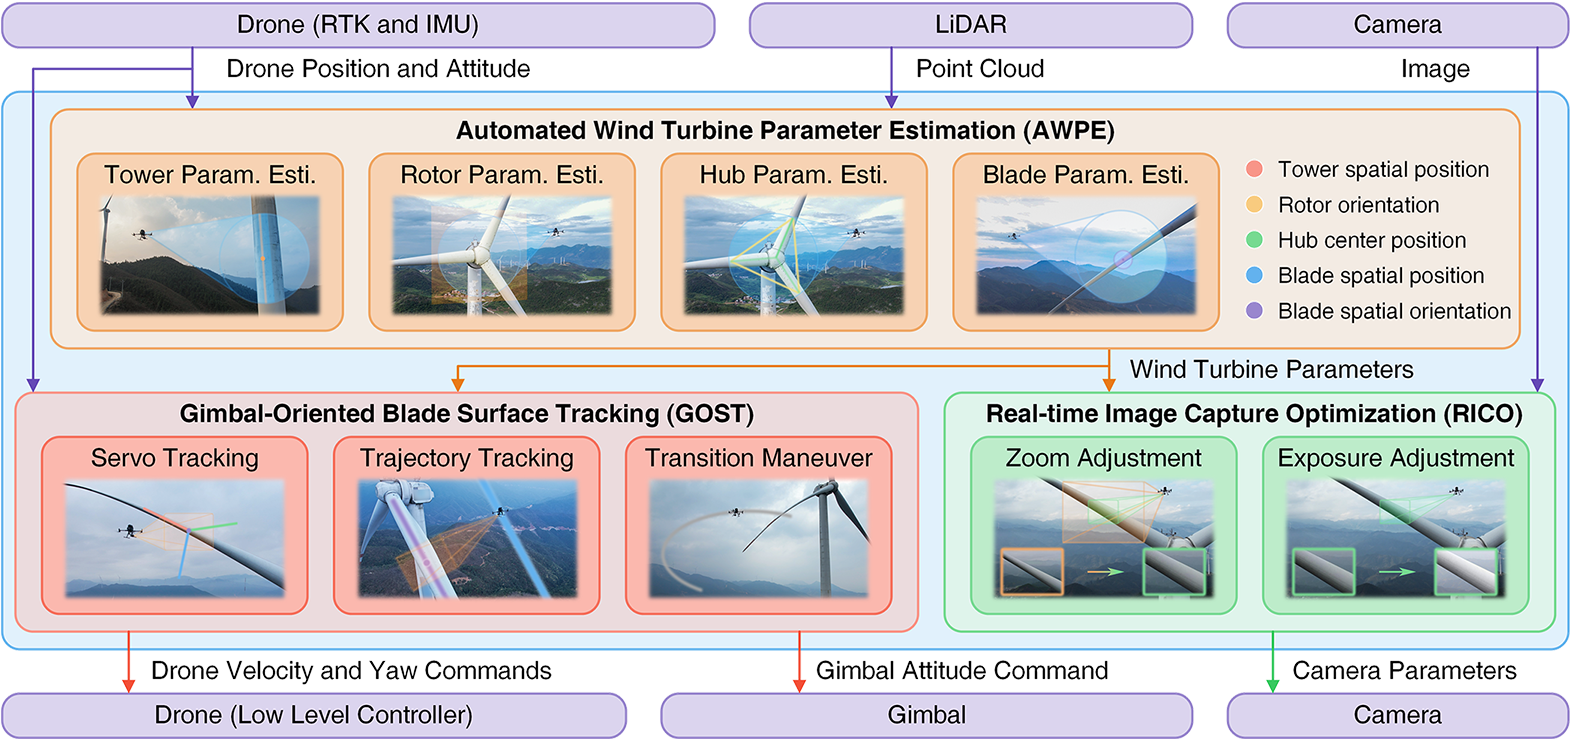
Utilizing the onboard sensors, the point cloud and image, along with the drone position and attitude, are acquired. The Automated Wind Turbine Parameter Estimation (AWPE) module estimates the wind turbine parameters, followed by the Gimbal-Oriented Blade Surface Tracking (GOST) module for blade surface tracking, and the Real-Time Image Quality Optimization (RIQO) module for real-time image quality optimization. The resulting drone velocity command, gimbal attitude command, and camera parameters combine to enable blade surface inspection and image acquisition.
Hardware Platform
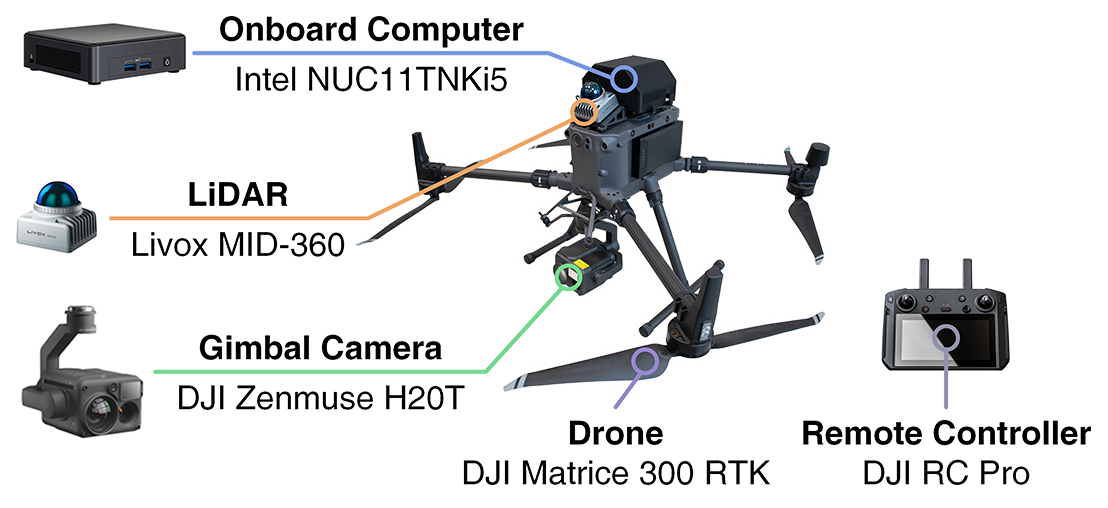
The hardware platform mainly consists of a drone, a LiDAR, a gimbal camera, an onboard computer, and a remote controller, possessing capabilities of large-range spatial perception and high-quality image acquisition.
Inspection Process
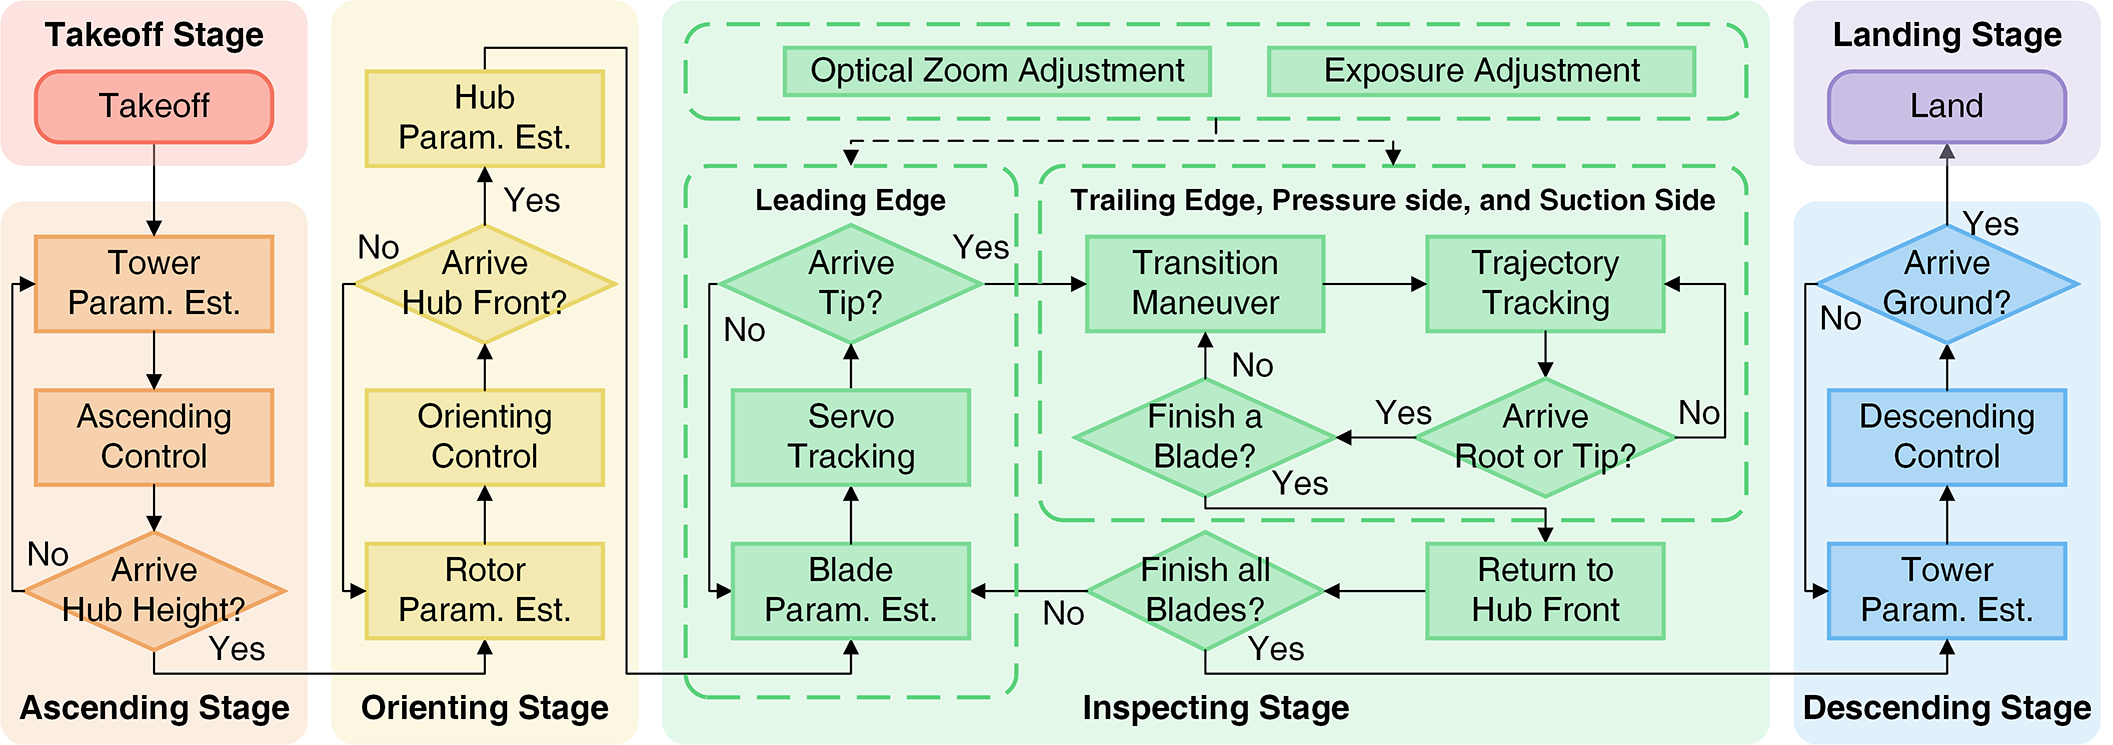
The inspection process comprises 6 stages: takeoff, ascending, orienting, inspecting, descending, and landing. In the inspecting stage, the drone sequentially inspects 4 surfaces of each blade. (Abbreviations: Param. Est.: Parameter Estimation)